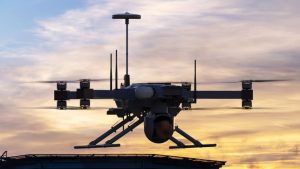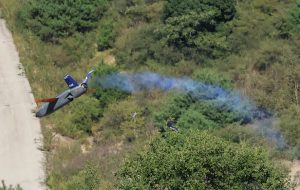
SandboxAQ has successfully flight-tested its AQNav quantum magnetic navigation software on Northrop Grumman’s Lumberjack Group 3 unmanned aircraft system. The demonstration marked the first reported flight of a magnetic navigation system on an attritable platform, as well as the initial pairing of magnetic and visual navigation on a one-way attack drone.
Engineers installed the hardware-agnostic AQNav software onto the existing onboard computing architecture of the Lumberjack drone in under an hour. The software processes sensor data in real-time, utilizing physics-based models to deliver continuous, unjammable positioning without relying on satellite signals. This capability is designed to support operations in GPS-denied and electronic warfare environments where traditional positioning systems are compromised, reported in the SandboxAQ press release.
Highlighting the importance of resilient alternative navigation, Max Schuster, program manager for the Lumberjack platform at Northrop Grumman, noted that collaborating with SandboxAQ enhances autonomous systems with flight-hardened navigation capabilities designed to function in contested domains. Similarly, Luca Ferrara, general manager of navigation at SandboxAQ, emphasized that the software architecture enables rapid integration into uncrewed platforms at scale.
The flight builds on ongoing testing with military and commercial aerospace partners, including multi-year evaluations with the United States Air Force aboard C-17 and C-130J transport aircraft, as well as participation in the Defense Innovation Unit’s Transition of Quantum Sensing program.